I am a master's student in Computer Science at the University of Virginia, advised by Professor Yen-Ling Kuo. My research connects embodied AI, computer vision, and language, with a focus on part-guided manipulation and long-horizon interactive robotics.
Previously, I studied Computer Science at Penn State University, graduating in 2024. My earlier work explored medical image analysis, self-supervised learning, and uncertainty-aware segmentation.
I investigate how robots can turn object-part understanding into accurate, reliable physical interaction. Across complementary approaches to representation, action learning, and execution, I study how visual observations, robot state, and available demonstrations can support precise interaction and extend it into sustained manipulation and longer tasks. A longer-term goal is to reduce dependence on privileged simulator information and support useful assistance in real environments.
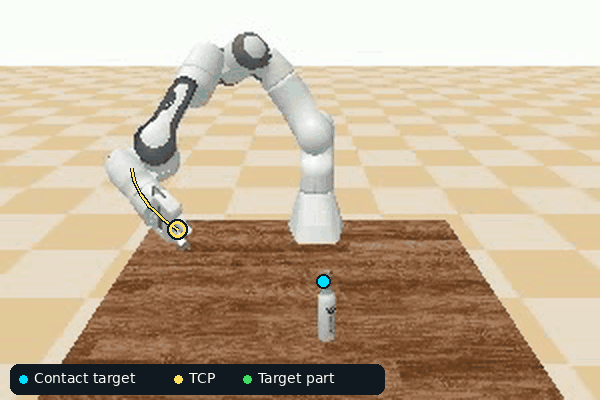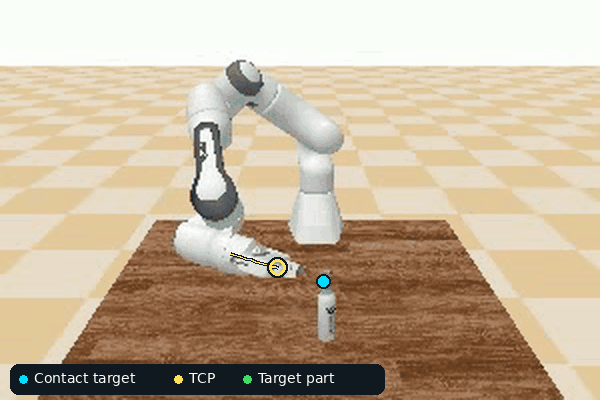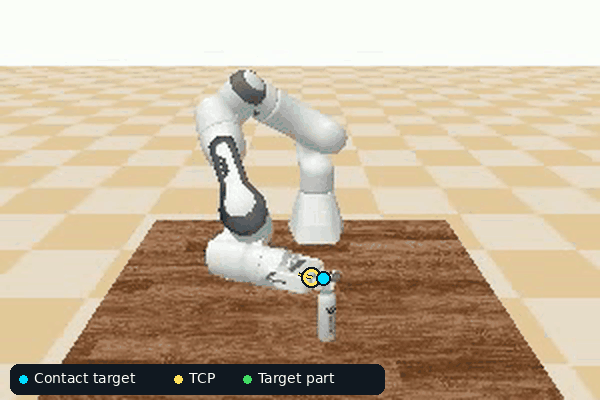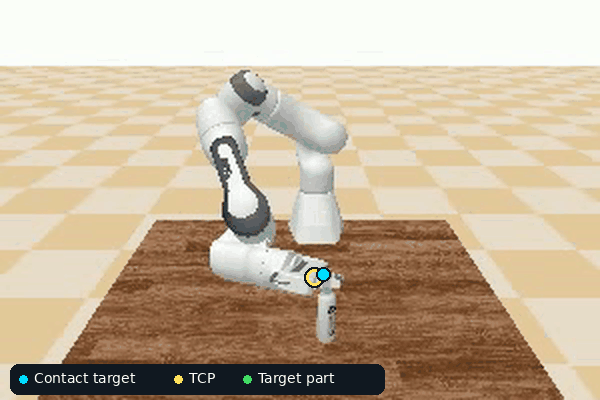
Part-guided bottle manipulation.
Part2Action
Part-guided robotic manipulation
Enable robots to follow instructions about specific object parts, such as “grasp the bottle at its neck.”
Investigate how part grounding, predicted contact geometry, and temporal action learning connect an intended interaction to robot motion.
Compare matched policies with and without geometry conditioning throughout the motion, examining how representation and control affect accurate part-guided interaction.
Use these experiments to work toward sustained manipulation and human–robot assistance.
Master's research · Advised by Professor Yen-Ling Kuo
YOLO-SCSA: Enhanced YOLOv8 with Spatially Coordinated Shuffling Attention Mechanisms for Skin Cancer Detection Jinyoon Kim, Tianjie Chen, Hien Nguyen, and Md Faisal Kabir. In Proceedings of IEEE International Conference on Machine Learning and Applications (ICMLA 2024), pp. 408-415, Dec 15, 2024. [ paper | GitHub ]
Automated Image Segmentation Using Self-Iterative Training and Self-Supervised Learning with Uncertainty Scores Jinyoon Kim, Tianjie Chen, and Md Faisal Kabir. In Book of Recent Advances in Deep Learning Applications: New Techniques and Practical Examples, Chapter 1, April 4, 2025. [ paper | GitHub | Book Weblink ]
Automated Data Labeling for Object Detection via Iterative Instance Segmentation Jinyoon Kim and Md Faisal Kabir. In Proceedings of IEEE International Conference on Machine Learning and Applications (ICMLA 2023), pp. 845-850, Dec 15, 2023. [ paper | poster | GitHub ]
Selected UVA projects
Robotic manipulation Ongoing
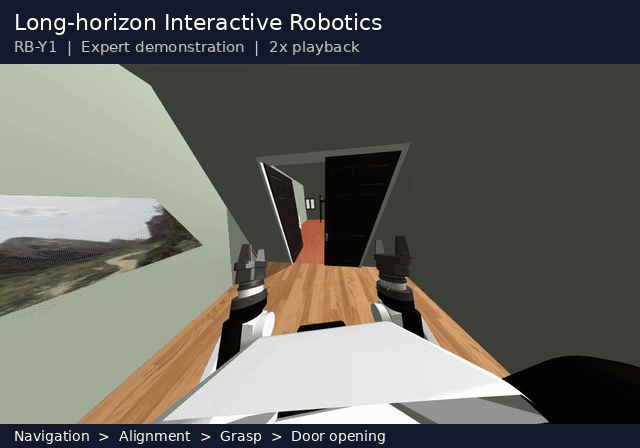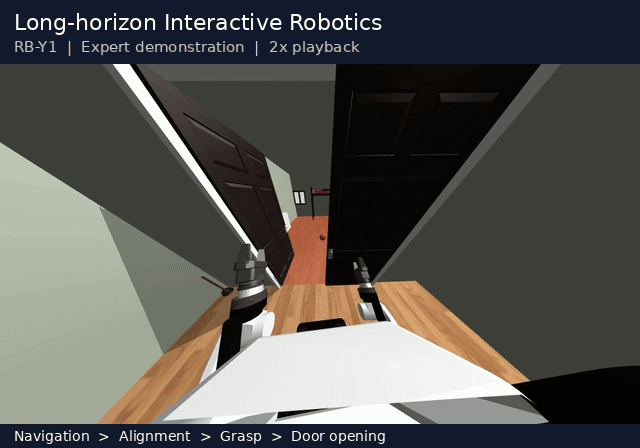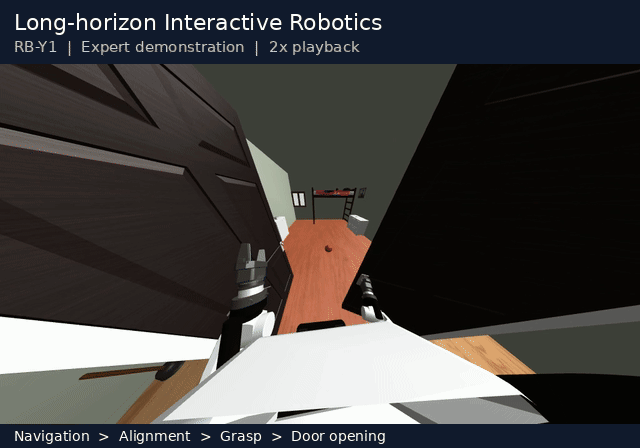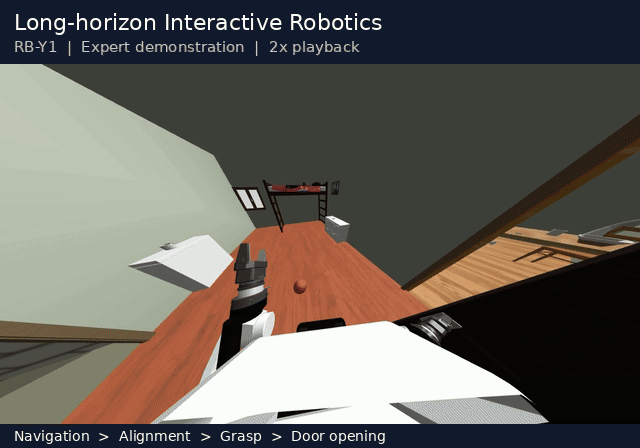
Part-Aware Interaction Poses for Stable Door Grasping
Explore explicit interaction-pose prediction as a complementary route from object-part understanding to physical action, using RGB observations, robot state, and simulator-derived handle points.
Train a pose predictor from expert demonstrations and combine it with local grasp control around frozen MolmoBot for RB-Y1 door manipulation in MolmoSpaces.
Evaluate both door opening and sustained grasp retention to understand how precise initial interaction can develop into continued manipulation.
Developed an end-to-end pipeline for editing unbounded Mip-NeRF 360 scenes using 3D Gaussian Splatting.
Engineered a custom "Occlusion-Aware Lifting" algorithm to bridge 2D semantics (GroundingDINO + SAM 2) with 3D geometry, enabling precise zero-shot object selection.
Integrated LaMa for multi-view consistent inpainting (removal) and GaussianDreamer for inserting generative 3D assets (addition), solving the "Artichoke Problem" in volumetric editing.
Developed a comprehensive ablation study comparing Deep Contextual RL (PPO, GRPO, RLOO, DPO) against Heuristic Bandits for the FinQA task.
Engineered a "Discriminative Reranking" pipeline to bypass generation failures, successfully training Llama-3.2-3B and TinyLlama-1.1B models.
Demonstrated that RL provides massive gains for weak learners (+35% accuracy on 1B models) while establishing the "SFT Ceiling" effect on capable 3B models.
Penn State University
Earlier projects
Capstone Project: Skin Cancer Detection Web Application (2024)
Created a mobile application for detecting plant diseases using neural networks.
Developed and fine-tuned MobileNet specifically for plant disease detection on mobile devices.
The resulting application runs efficiently and accurately classifies plant disease images in a mobile environment.
Awards & honors
2024
National Ackroyd Healthier Days Scholarship
Recognized for a skin cancer detection application developed with the Ackroyd Family Foundation and Penn State community.
2023
Penn State Computer Science Department Undergraduate Student Award
Recognized for presenting research on self-supervised automated image segmentation at ICMLA 2023.
Conference highlights
Pennsylvania State University Capstone Project Conference 2024. May 1, 2024. I attended the Penn State Capstone Project Conference 2024 as a member of the Capstone Project Team. Thanks to Professor Nguyen, Professor Kabir, and my colleague Tianjie Chen.
IEEE International Conference on Machine Learning and Applications (IEEE ICMLA 2023). December 15, 2023. I attended ICMLA 2023 with the poster of my paper for the presentation. Thanks for Dr. Kabir and everyone I met at the conference.
[ieee website]